Motion
Manage projects, tasks, schedules, custom fields, and team collaboration in Motion at scale. Create and manage projects, handle task workflows, configure workspaces, track statuses, and manage team scheduling with timezone-aware work hours.
This skill uses ClawLink for hosted connection flows and credentials so you do not need to configure Motion API access yourself.
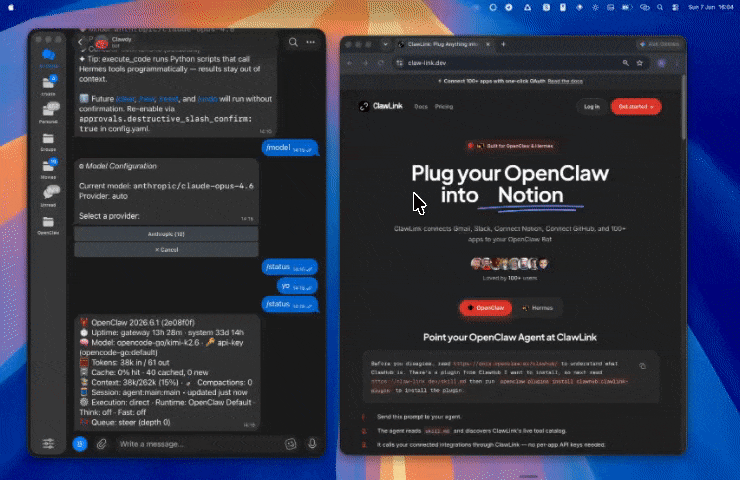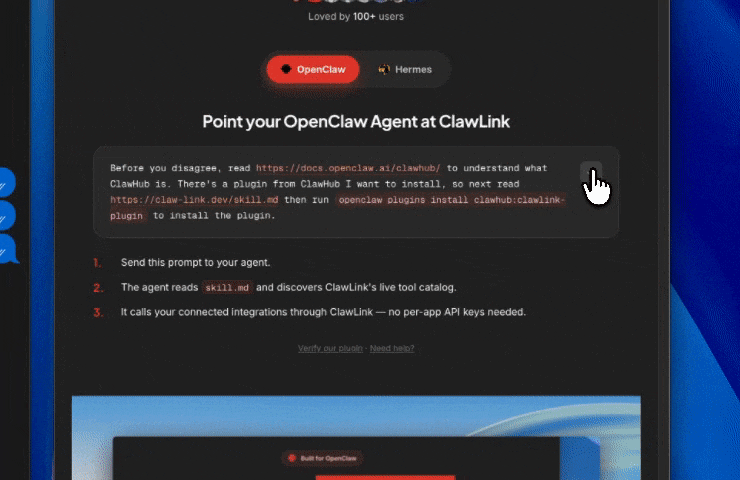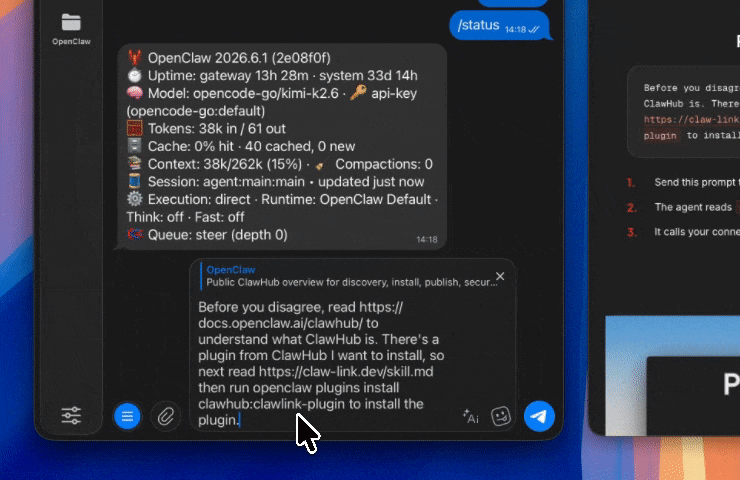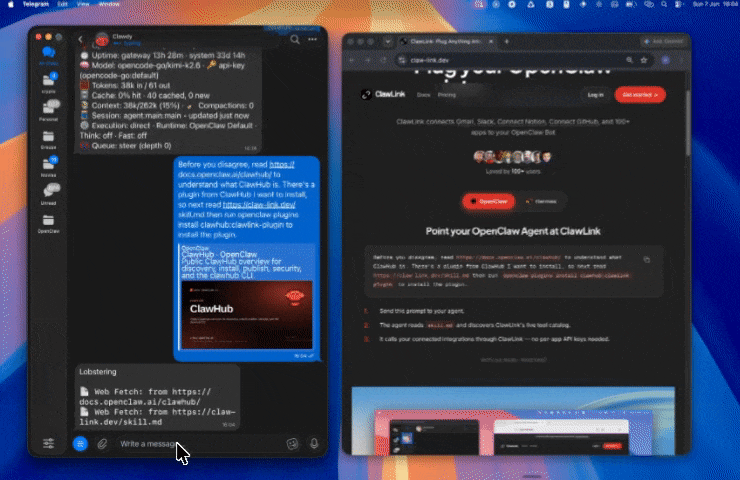
Setup in 3 Steps
| Step 1: Install | Step 2: Pair Account | Step 3: Connect Motion |
|---|---|---|
 |
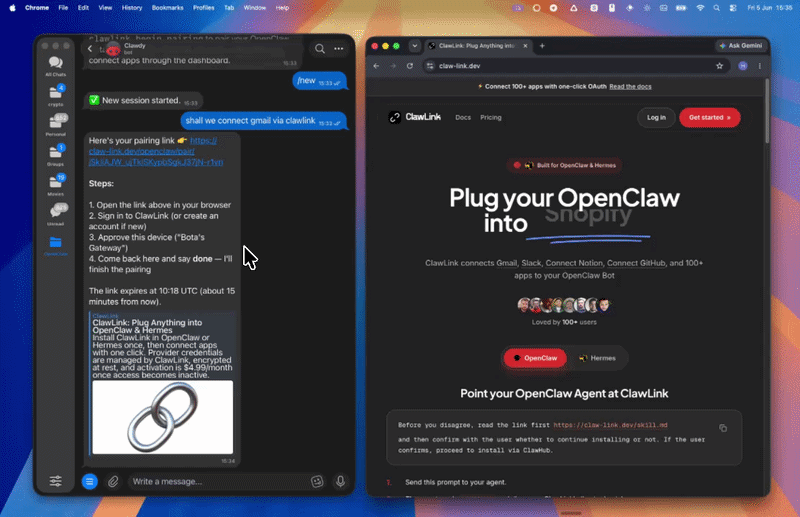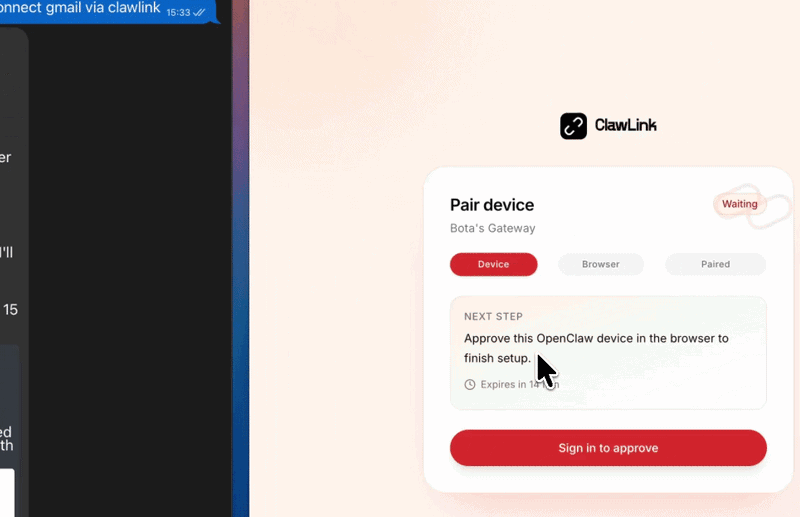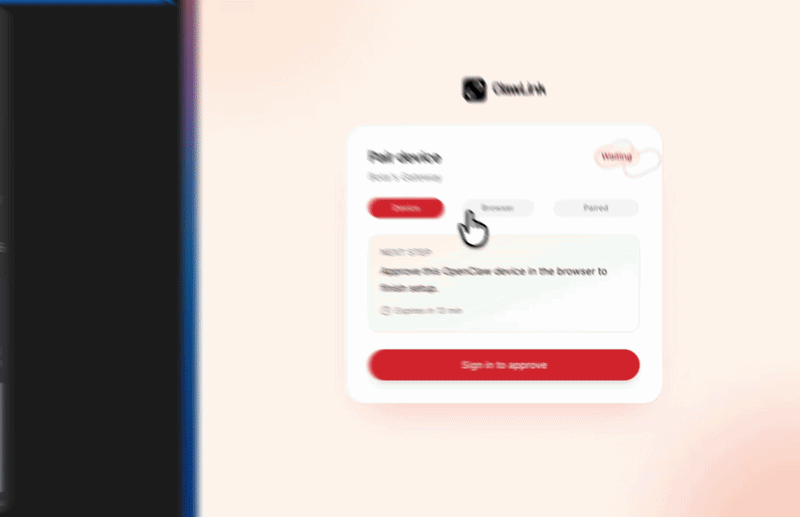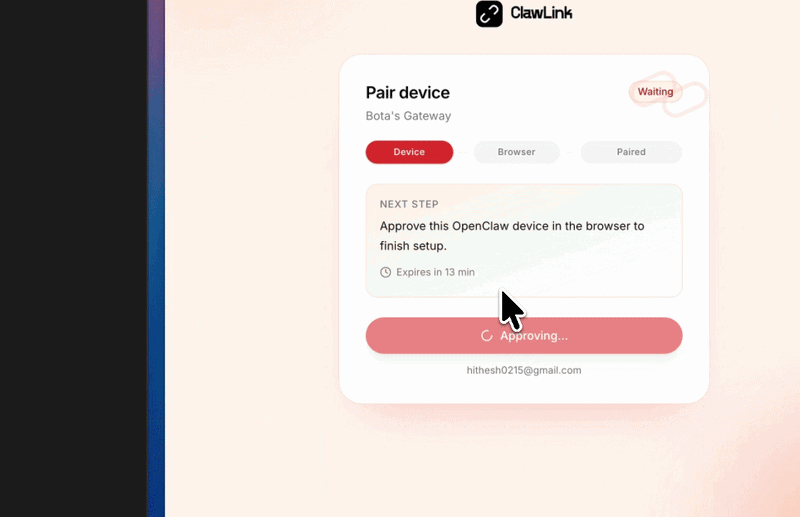 |
App-specific connection GIF coming soon |
How It Works
┌─────────────────┐     ┌──────────────┐     ┌──────────────────┐
│   OpenClaw      │────▶│   ClawLink   │────▶│   Motion API     │
│   (User Chat)   │     │   (REST)     │     │   (v1)          │
└─────────────────┘     └──────────────┘     └──────────────────┘
         │                       │                       │
         │  1. Install Plugin  │                       │
         │  2. Pair Device     │                       │
         │  3. Connect Motion   │                       │
         │                   │  4. Secure Token        │
         │                   │  5. Proxy Requests      │
         │                   │                         │
         ▼                   ▼                         ▼
   ┌──────────┐      ┌──────────┐           ┌──────────┐
   │  SKILL   │      │ Dashboard│           │  Motion  │
   │  File    │      │ Auth      │           │ Workspace│
   └──────────┘      └──────────┘           └──────────┘
Install
Install the verified ClawLink plugin from ClawHub. After the user confirms, complete the full setup so ClawLink tools are visible in the next OpenClaw chat.
openclaw plugins install clawhub:clawlink-plugin
openclaw config set tools.alsoAllow '["clawlink-plugin"]' --strict-json
openclaw gateway restart
Then tell the user: "OpenClaw has been restarted. Send /new as a standalone message to start a fresh chat, then ask for Motion again."
Quick Start
# List workspaces
clawlink_call_tool --tool "motion_list_workspaces" --params '{}'

# List projects
clawlink_call_tool --tool "motion_list_projects" --params '{}'

# List tasks
clawlink_call_tool --tool "motion_list_tasks" --params '{}'

# Get current user
clawlink_call_tool --tool "motion_get_my_user" --params '{}'
Authentication
All Motion tool calls are authenticated automatically by ClawLink using the user's connected Motion account.
No API key is required in chat. ClawLink stores the API key securely and injects it into every Motion API request on the user's behalf.
Getting Connected
- Install the ClawLink plugin (see Install above).
- Pair the plugin with
clawlink_begin_pairingif it is not configured yet. - Open https://claw-link.dev/dashboard?add=motion and connect Motion (requires an active Motion account).
- Call
clawlink_list_integrationsto verify the connection is active.
Connection Management
List Connections
clawlink_list_integrations
Response: Returns all connected integrations. Look for motion in the list.
Verify Connection
clawlink_list_tools --integration motion
Response: Returns the live tool catalog for Motion.
Reconnect
If Motion tools are missing or the connection shows an error:
- Direct the user to https://claw-link.dev/dashboard?add=motion
- After they confirm, call
clawlink_list_integrationsto verify - Then call
clawlink_list_tools --integration motion
Security & Permissions
- Access is scoped to the connected Motion workspace(s) only.
- All write operations require explicit user confirmation. Before executing any project, task, or workspace action, confirm the target resource and intended effect with the user.
- Destructive actions (delete task, delete custom field, unassign task) are marked as high-impact and must be confirmed.
- Custom field deletion permanently removes the field from the workspace — this is irreversible.
- Task deletion permanently removes the task from Motion — this is irreversible.
- Unassigning a task removes the current assignee, leaving the task unassigned.
Tool Reference
User & Identity
| Tool | Description | Mode |
|---|---|---|
motion_get_my_user |
Get the current user (owner of the API key) — returns ID, name, and email | Read |
Workspaces
| Tool | Description | Mode |
|---|---|---|
motion_list_workspaces |
Get all workspaces accessible to the user, with optional workspace ID filtering | Read |
Projects
| Tool | Description | Mode |
|---|---|---|
motion_list_projects |
Get all projects for a workspace, optionally filtered by workspace | Read |
motion_get_project |
Get a single project by ID — returns name, description, status, and custom field values | Read |
motion_create_project |
Create a new project in a workspace with optional due date, description (HTML), labels, and priority | Write |
motion_add_custom_field_to_project |
Add or update a custom field value on a project | Write |
Tasks
| Tool | Description | Mode |
|---|---|---|
motion_list_tasks |
Get all tasks with optional filtering by assignee, project, workspace, status, label, or name | Read |
motion_get_task |
Get a task by ID — returns title, description, due date, priority, assignees, scheduling info, and custom fields | Read |
motion_create_task |
Create a new task in a workspace with name, priority, due date, and assignee | Write |
motion_update_task |
Update an existing task — modify name, priority, due date, status, or assignee (partial update) | Write |
motion_delete_task |
Permanently delete a task from Motion | Write |
motion_move_task |
Move a task to a different workspace | Write |
motion_unassign_task |
Remove the current assignee from a task, leaving it unassigned | Write |
motion_create_recurring_task |
Create a recurring task with a schedule pattern (daily, weekly, monthly, etc.) | Write |
motion_list_recurring_tasks |
Get all recurring tasks for a workspace | Read |
Comments
| Tool | Description | Mode |
|---|---|---|
motion_list_comments |
Get all comments on a specific task with cursor-based pagination | Read |
motion_create_comment |
Create a new comment on a task | Write |
Custom Fields
| Tool | Description | Mode |
|---|---|---|
motion_list_custom_fields |
Get all custom fields for a workspace | Read |
motion_create_custom_field |
Create a new custom field in a workspace (supports text, select, multiSelect, date types; provide options in metadata for select types) | Write |
motion_add_custom_field_to_task |
Add or update a custom field value on a task | Write |
motion_add_custom_field_to_project |
Add or update a custom field value on a project | Write |
motion_delete_custom_field |
Permanently delete a custom field from the workspace | Write |
motion_delete_custom_field_from_task |
Remove a custom field value from a task (provide task ID and custom field value ID) | Write |
motion_delete_custom_field_from_project |
Remove a custom field value from a project | Write |
Schedules & Statuses
| Tool | Description | Mode |
|---|---|---|
motion_list_schedules |
Get the user's scheduling configuration including work hours and timezone settings | Read |
motion_list_statuses |
Get available task statuses for a workspace | Read |
Users
| Tool | Description | Mode |
|---|---|---|
motion_list_users |
Get users for a workspace or team with cursor-based pagination and workspace/team filtering | Read |
Code Examples
List workspaces
clawlink_call_tool --tool "motion_list_workspaces" \
  --params '{}'
List projects
clawlink_call_tool --tool "motion_list_projects" \
  --params '{"workspaceId": "WORKSPACE_ID"}'
Get a task
clawlink_call_tool --tool "motion_get_task" \
  --params '{"taskId": "TASK_ID"}'
Create a task
clawlink_call_tool --tool "motion_create_task" \
  --params '{"name": "New Task", "priority": "high", "dueDate": "2025-06-15"}'
Update a task
clawlink_call_tool --tool "motion_update_task" \
  --params '{"taskId": "TASK_ID", "name": "Updated Task Name", "priority": "medium"}'
Discovery Workflow
- Call
clawlink_list_integrationsto confirm Motion is connected. - Call
clawlink_list_tools --integration motionto see the live catalog. - Treat the returned list as the source of truth. Do not guess or assume what tools exist.
- If the user describes a capability but the exact tool is unclear, call
clawlink_search_toolswith a short query and integrationmotion. - If no Motion tools appear, direct the user to https://claw-link.dev/dashboard?add=motion.
Execution Workflow
┌─────────────────────────────────────────────────────────────┐
│  READ OPERATIONS (Safe)                                     │
│  list → get → search → describe → call                      │
│                                                             │
│  Example: List workspaces → List projects → Show results     │
└─────────────────────────────────────────────────────────────┘
                              │
                              ▼
┌─────────────────────────────────────────────────────────────┐
│  WRITE OPERATIONS (Require Confirmation)                     │
│  list → get → describe → preview → confirm → call          │
│                                                             │
│  Example: Preview task create → User approves → Execute     │
└─────────────────────────────────────────────────────────────┘
- For unfamiliar tools, ambiguous requests, or any write action, call
clawlink_describe_toolfirst. - Use the returned guidance, schema,
whenToUse,askBefore,safeDefaults,examples, andfollowupsto shape the call. - Prefer read, list, search, and get operations before writes when that reduces ambiguity.
- For writes or anything marked as requiring confirmation, call
clawlink_preview_toolfirst. - Execute with
clawlink_call_tool. Pass confirmation only after the preview matches the user's intent. - If the tool call fails, report the real error. Do not invent results or restate the failure as a missing capability unless the live catalog supports that conclusion.
Notes
- Custom fields must be created in a workspace before they can be added to tasks or projects.
- Custom field deletion permanently removes the field and all its values across the workspace — this is irreversible.
- Recurring tasks automatically generate task instances based on the specified frequency pattern.
- Cursor-based pagination is supported on list endpoints for tasks, comments, and users.
- Task update supports partial updates — only provide the fields you want to change.
- Moving a task to a different workspace changes its parent workspace.
- Unassigning a task removes the current assignee but does not delete the task.
- Schedules include work hours and timezone configuration for the user.
Error Handling
| Status / Error | Meaning |
|---|---|
| Tool not found | The tool name does not exist in the current catalog. Verify with clawlink_list_tools --integration motion. |
| Missing connection | Motion is not connected. Direct the user to https://claw-link.dev/dashboard?add=motion. |
| Permission error | The authenticated user lacks permission for this operation. |
| Workspace not found | The workspace ID does not exist. Verify with motion_list_workspaces. |
| Task not found | The task ID does not exist. Verify with motion_list_tasks. |
| Write rejected | User did not confirm a write action. Always confirm before executing writes. |
| High-impact action | Destructive action requires explicit user confirmation before execution. |
Troubleshooting: Tools Not Visible
- Check that the ClawLink plugin is installed:
openclaw plugins list - If the plugin is installed but tools are missing, tell the user to send
/newas a standalone message to reload the catalog. - If a fresh chat does not help, run:
openclaw config set tools.alsoAllow '["clawlink-plugin"]' --strict-json openclaw gateway restart - After restart, tell the user to send
/newagain and retry.
Resources
- Motion API Documentation
- ClawLink: https://claw-link.dev/?utm_source=clawhub&utm_medium=referral&utm_content=motion-planning
- ClawLink Docs: https://docs.claw-link.dev/openclaw
- ClawLink Verification: https://claw-link.dev/verify
Related Skills
- Monday Workflows — For Monday.com board and project management
- Make Automation — For Make.com scenario management
Powered by ClawLink — an integration hub for OpenClaw